Anticipate weak observations
Ray tracing supports predictions of the information available to the sensor.
IEEE RA-L · 2025 / PERCEPTION & CONTROL
Move the sensor where the information is.
Uncertainty-aware control that adapts a motorized LiDAR’s scanning motion to the surrounding geometry.
01 / OVERVIEW
UA-MPC: Uncertainty-Aware Model Predictive Control for Motorized LiDAR Odometry
IEEE Robotics and Automation Letters · 2025
A motorized LiDAR can change its scanning direction. UA-MPC uses predicted observability to choose that motion, balancing sensing accuracy and efficiency as the system encounters different environments.
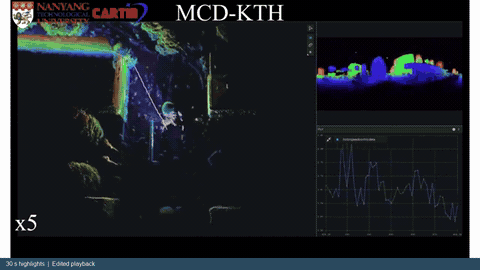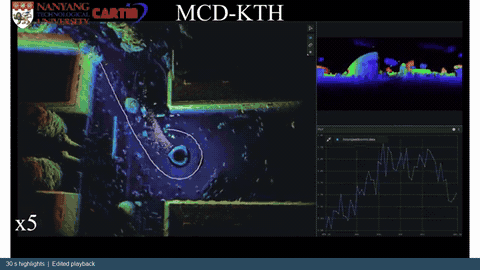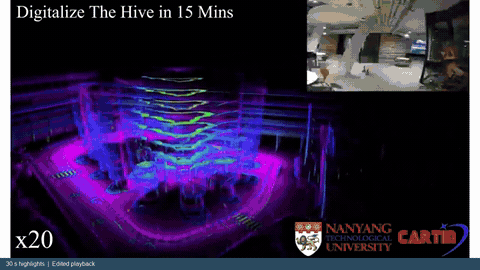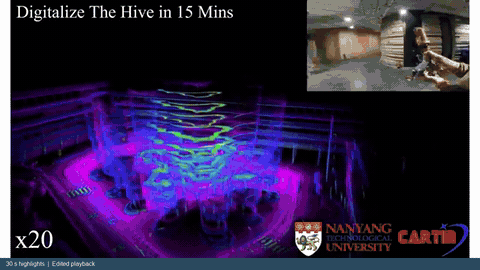
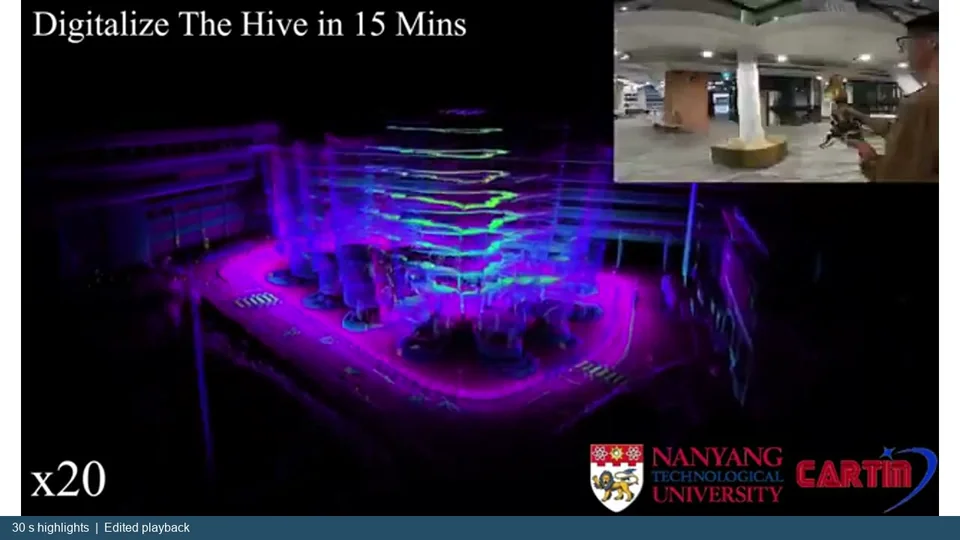
RESEARCH VISUALS · 30 sec
A short preview from the coauthor’s UA-MPC materials. The original link opens the NTU Hive experiment.
02 / IMPLEMENTATION
Observe the nearby environment.
Estimate future observability from geometry.
Select motor motion with predictive control.
Use the resulting scans for odometry.
Ray tracing supports predictions of the information available to the sensor.
Model predictive control adjusts the motor instead of fixing its speed.
The demonstrations include the NTU Hive and Spine environments.
03 / RESOURCES
The paper, original demonstrations, and available project materials.