Create a useful sensing geometry
Controlled rotation changes the range observations over time.
IEEE TIE · Accepted · 2026 / UWB LOCALIZATION
Recover 3D position from a single rotating anchor.
Three-dimensional robot localization using one rotating UWB anchor and a two-stage estimator.
01 / OVERVIEW
Three-Dimensional Robotic Localization via a Single Rotating Ultra-Wideband Anchor
IEEE Transactions on Industrial Electronics · 2026 · Accepted for publication
A rotating ultra-wideband anchor introduces a time-varying measurement geometry. This work uses that geometry for three-dimensional localization and combines geometric initialization with an extended Kalman filter using range and velocity measurements in an externally aligned frame.
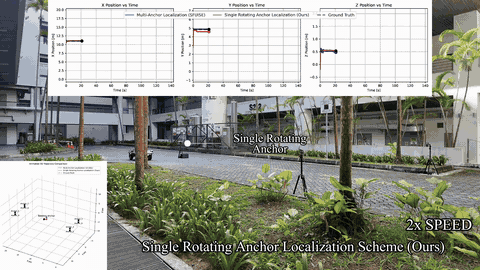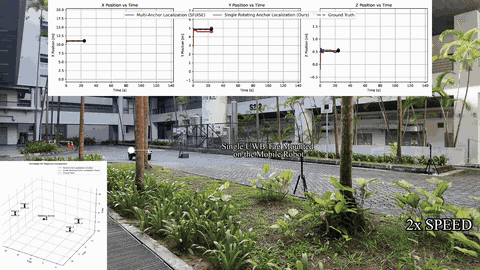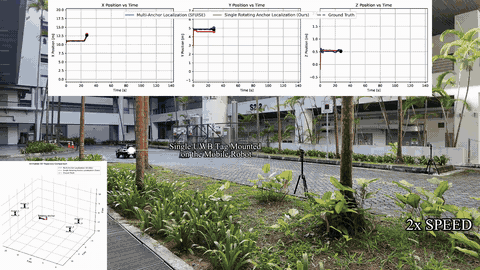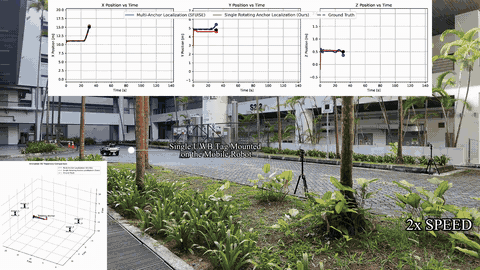
RESEARCH VISUALS · 35 sec
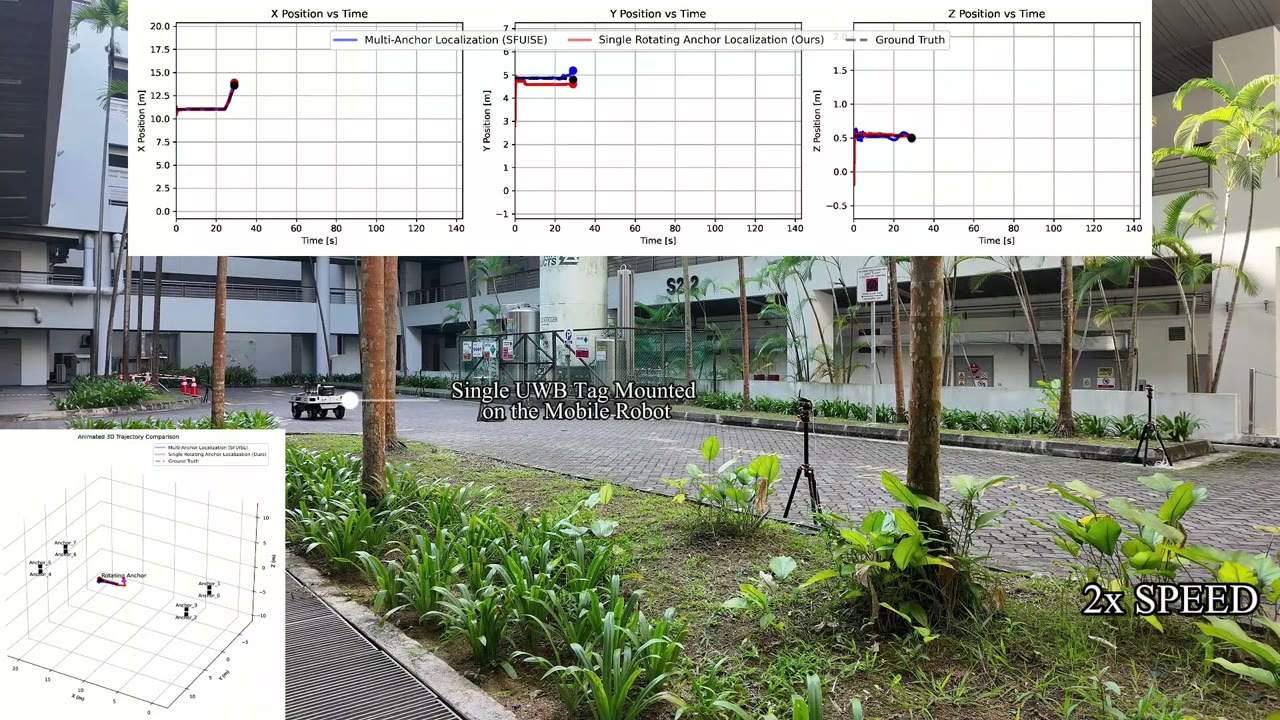
An outdoor experiment excerpt (308–343 s) from the original supplementary video, with the original 2× speed label and position plots retained. Open the original video for the complete demonstration.
02 / IMPLEMENTATION
Move the anchor along a known circular path.
Collect distances to the target tag.
Estimate position from accumulated measurements.
Update the position through filtering.
Controlled rotation changes the range observations over time.
The two-stage estimator combines initialization and recursive tracking.
The study investigates measurement noise, rotation geometry, and target motion.
03 / RESOURCES
The paper, original demonstrations, and available project materials.