Make reconstruction an active task
The next observation is part of the reconstruction process.
Unmanned Systems · 2026 / PERCEPTION & CONTROL
Look closer. Move around. Reach what is hidden.
Multimodal agents that choose viewpoints and interact with objects to build more complete 3D reconstructions.
01 / OVERVIEW
AIR-Embodied: Active Interactive Reconstruction for 3D Gaussian Splatting with Embodied Multimodal Agents
Unmanned Systems · 2026
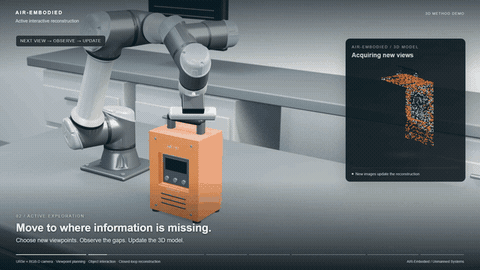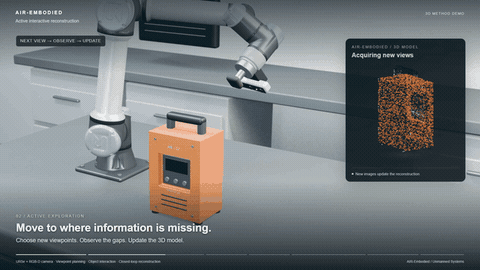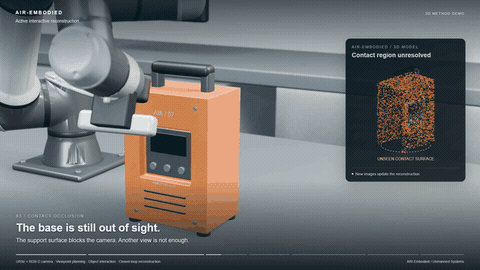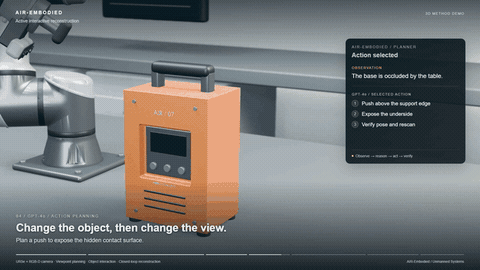
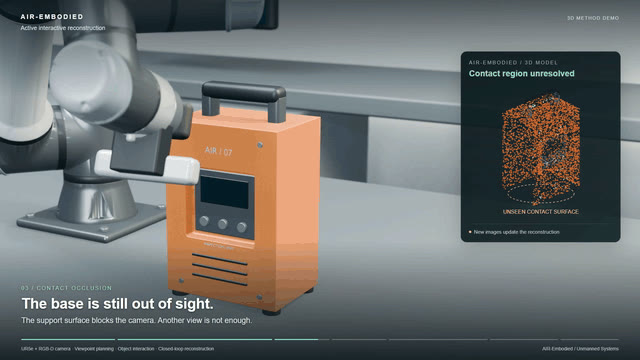
Active reconstruction requires deciding what to observe next. AIR-Embodied brings multimodal reasoning, viewpoint planning, and physical interaction into a 3D Gaussian Splatting pipeline, allowing the embodied system to address parts of a scene that passive observation leaves occluded.
RESEARCH VISUALS
Method preview from the coauthor’s project materials. The original video shows the full demonstration.
02 / IMPLEMENTATION
Capture the current view of the scene.
Identify incomplete or occluded regions.
Choose a new viewpoint or interact with an object.
Integrate the additional observations.
The next observation is part of the reconstruction process.
Multimodal agents connect scene interpretation with embodied actions.
Interaction creates opportunities to observe surfaces that were previously hidden.
03 / RESOURCES
The paper, original demonstrations, and available project materials.