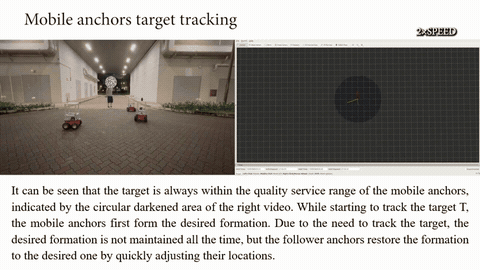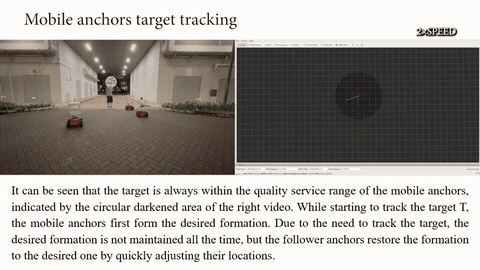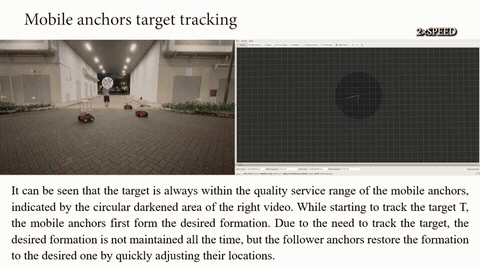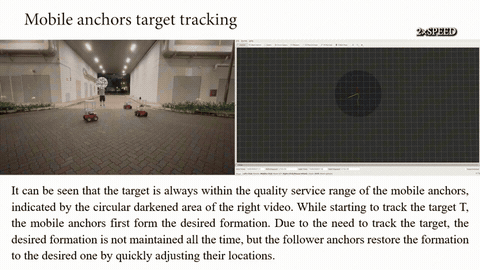
Replace fixed infrastructure
Robots carry the anchors instead of relying on a fixed deployment.
IEEE TASE · 2026 / UWB LOCALIZATION
Let the localization infrastructure move with you.
A team of mobile UWB anchors moves with the target to extend localization beyond a fixed installation.
01 / OVERVIEW
Extended Range of Localization Services via Formation-Controlled Mobile Ultra-Wideband Anchors
IEEE Transactions on Automation Science and Engineering · 2026
Fixed anchors limit where UWB localization is available. This work coordinates mobile anchors through formation control so that the sensing formation can move while continuing to provide localization services.
RESEARCH VISUALS · 33 sec
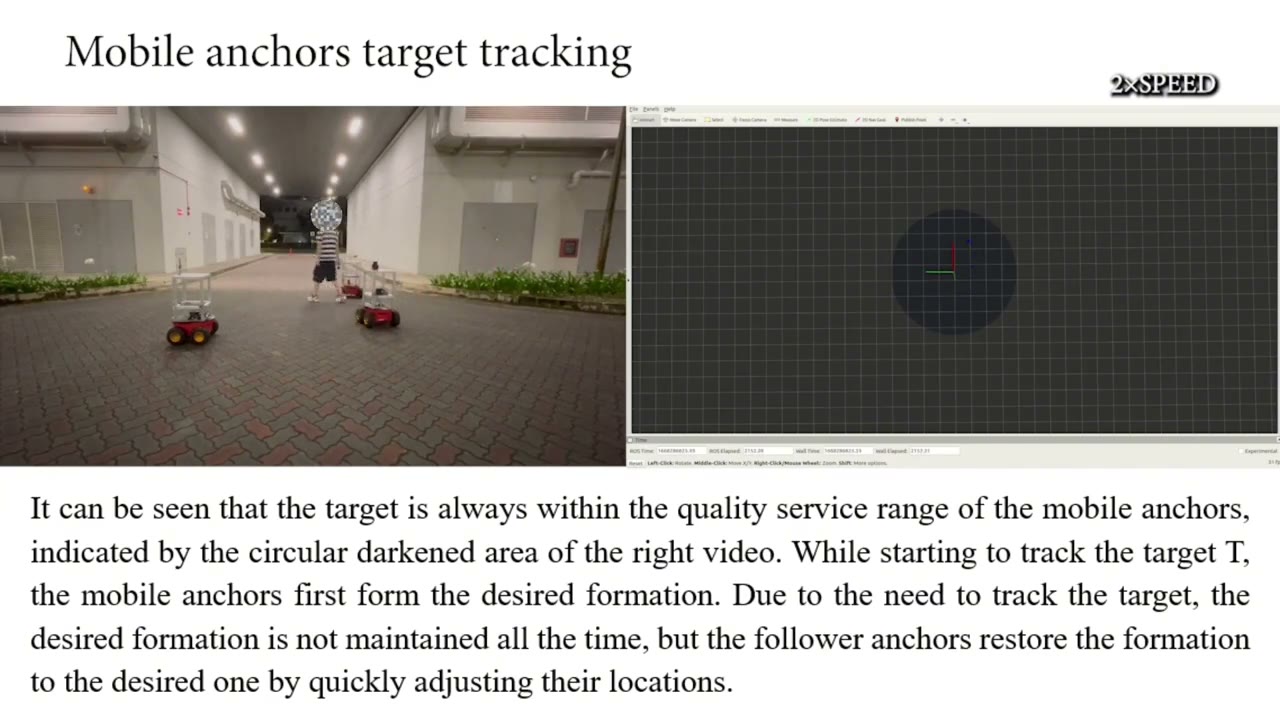
A 33-second outdoor experiment excerpt (198.8–232 s) from the original supplementary video. The formation and tracking views and original 2× speed label are preserved. Open the original video for the complete demonstration.
02 / IMPLEMENTATION
Collect UWB ranges within the system.
Estimate the target position.
Maintain a suitable anchor formation.
Extend coverage as the formation travels.
Robots carry the anchors instead of relying on a fixed deployment.
Formation control organizes the mobile anchors around the localization task.
The experiments show localization while the anchor team moves.
03 / RESOURCES
The paper, original demonstrations, and available project materials.