Model second-order motion
The formulation explicitly includes robot position and velocity dynamics.
CCDC · 2021 / COLLABORATIVE CONTROL
Coordinate positions and dynamics in one optimization.
A continuous-time distributed algorithm for collaborative lifting with second-order robot dynamics.
01 / OVERVIEW
An Optimization Algorithm for Second-order Multi-robot Collaborative Object Lifting
Chinese Control and Decision Conference (CCDC) · 2021
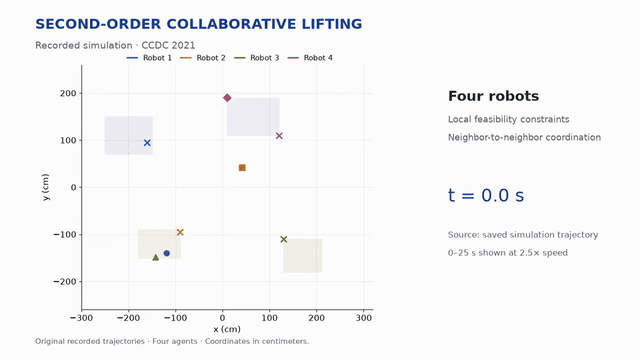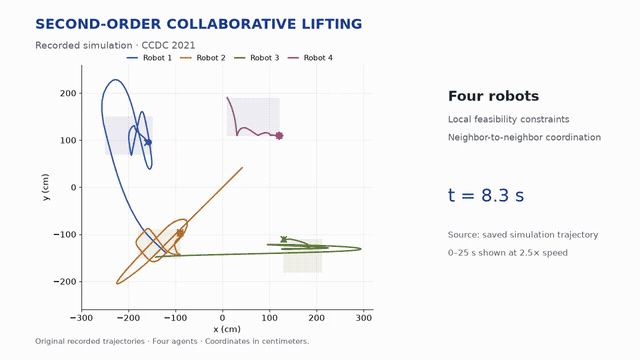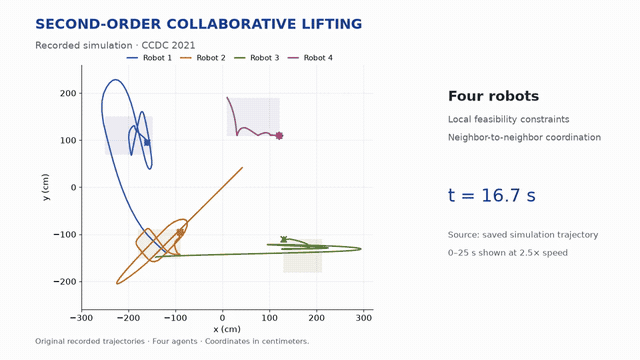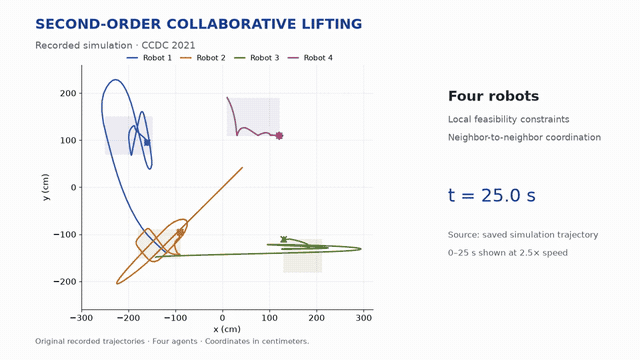
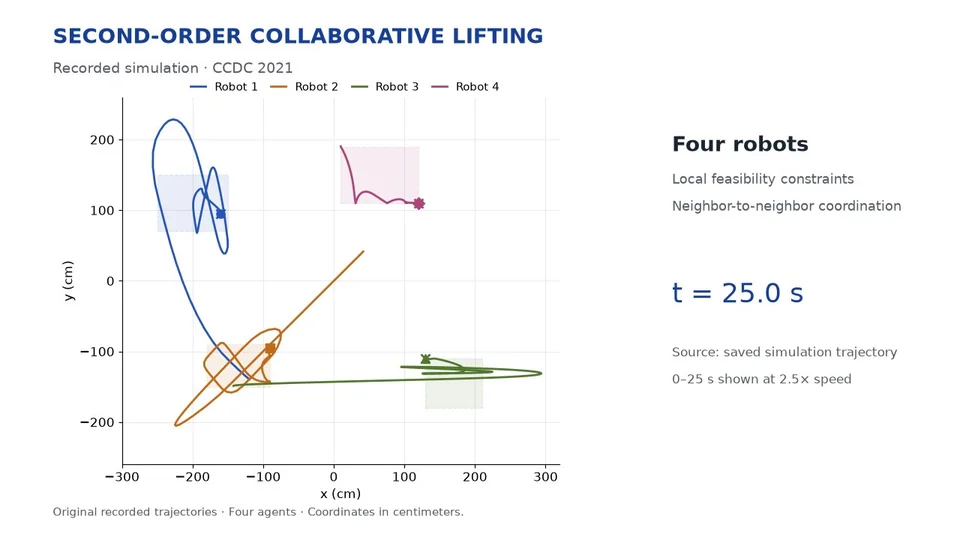
This study considers collaborative lifting by robots with second-order dynamics. A distributed algorithm seeks a feasible optimum while satisfying a coupled equality constraint that limits horizontal force imbalance.
RESEARCH VISUALS · 10 sec
Animation of the original saved simulation trajectories, rather than a physical robot experiment.
02 / IMPLEMENTATION
Evaluate each robot’s local objective.
Communicate auxiliary information with neighbors.
Evolve the second-order robot states.
Approach the constrained optimum.
The formulation explicitly includes robot position and velocity dynamics.
The algorithm uses local variables and neighbor communication.
The paper establishes convergence and presents a numerical simulation.
03 / RESOURCES
The paper, original demonstrations, and available project materials.