Encode safety and task requirements
Control barrier functions describe safety sets, while equality constraints express the shared task.
IEEE/ASME TMECH · 2025 / COLLABORATIVE CONTROL
Keep the shared task coordinated during human interaction.
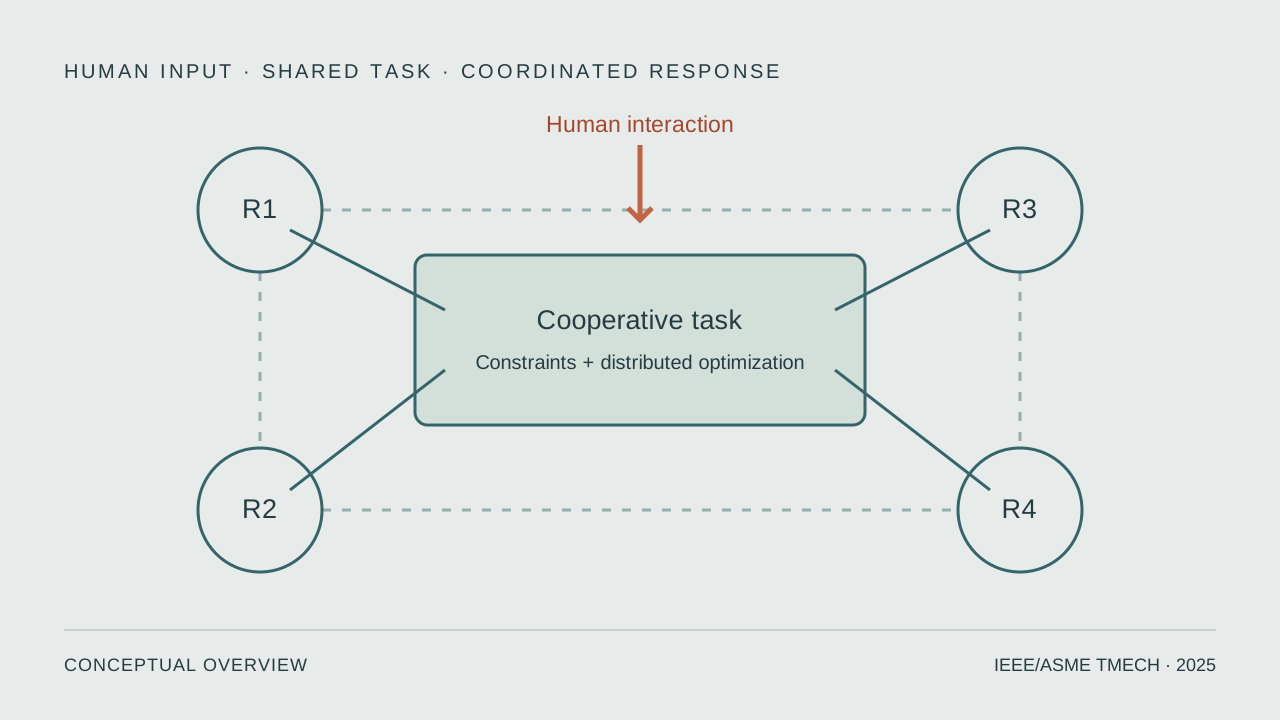
Distributed optimization for human intervention during cooperative robot tasks with task and safety constraints.
01 / OVERVIEW
Distributed Quadratic Programming for Safe Human Multirobot Interaction Under Task Constraints
IEEE/ASME Transactions on Mechatronics · 2025
Human intervention can change the motion required of a robot team during a cooperative task. This work encodes safety with control barrier functions and represents task requirements through equality constraints, then solves the resulting distributed quadratic programs through local computation and neighbor communication.
RESEARCH VISUALS
Conceptual illustration of the research problem; not experimental footage. A verified demonstration video is not currently available.
02 / IMPLEMENTATION
Receive the human intervention.
Express task and safety requirements.
Exchange information between robots.
Solve for coordinated robot motions.
Control barrier functions describe safety sets, while equality constraints express the shared task.
Discrepancy variables connect local problems and allow neighbor communication to coordinate the solution.
A recurrent network solves the local programs. The paper reports simulation and experimental evaluations.
03 / RESOURCES
The paper, original demonstrations, and available project materials.