Add motion to ranging
Rotation changes the measurement geometry without adding a fixed anchor network.
IEEE RA-L · 2023 / UWB LOCALIZATION
Turn a range measurement into relative position.
Relative localization between robots using a rotating UWB tag to enrich range-only measurements.
01 / OVERVIEW
Relative Localization Estimation for Multiple Robots via the Rotating Ultra-Wideband Tag
IEEE Robotics and Automation Letters · 2023
One distance measurement does not uniquely determine a robot’s relative position. A rotating UWB tag introduces a known motion into the ranging process, providing additional geometric information for estimating the relative locations of multiple robots.
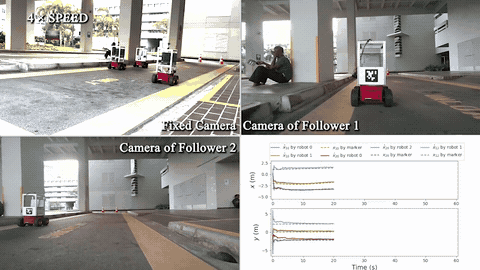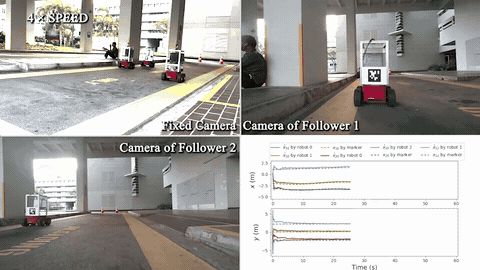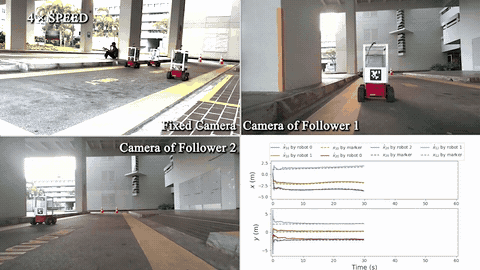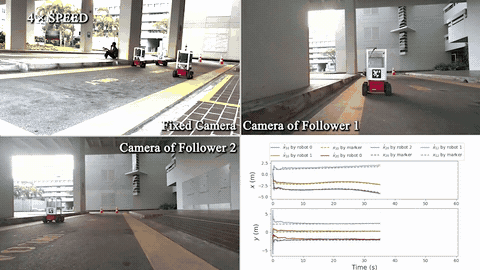
RESEARCH VISUALS · 34 sec
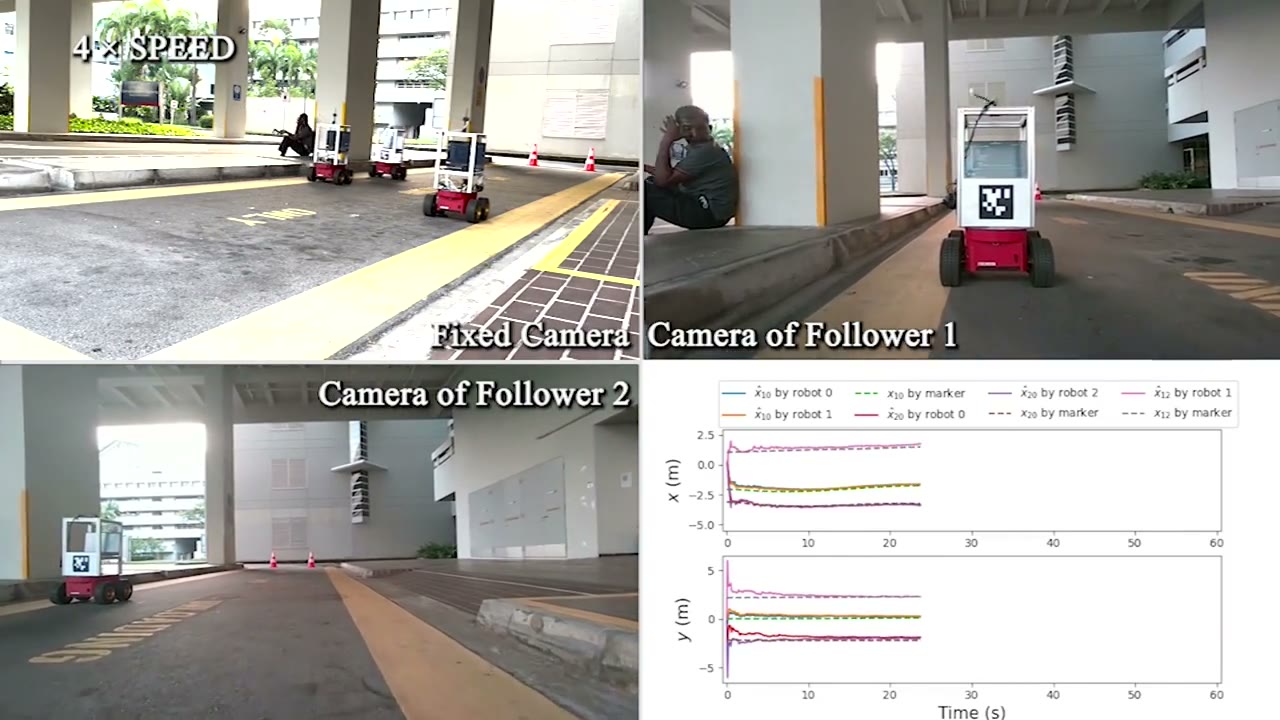
Selected excerpts from the original supplementary video: outdoor (27–40.8 s) and indoor (46–66 s) experiments. The source’s 4× / 2× speed labels and plots are retained. Open the original video for the complete demonstration.
02 / IMPLEMENTATION
Introduce a known motion to the UWB tag.
Collect ranges between robots.
Recover relative positions from the measurements.
Compare estimates in robot experiments.
Rotation changes the measurement geometry without adding a fixed anchor network.
The estimator uses the rotating-tag measurements for multi-robot localization.
The original video presents the system and experimental results.
03 / RESOURCES
The paper, original demonstrations, and available project materials.