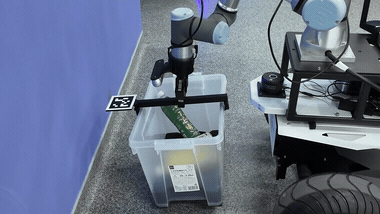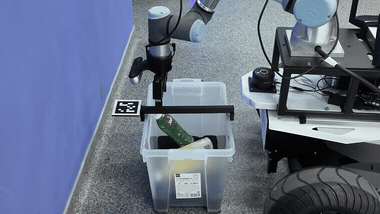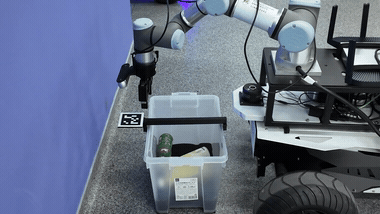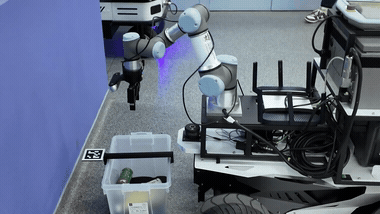
A mobile workspace
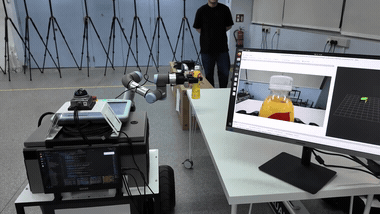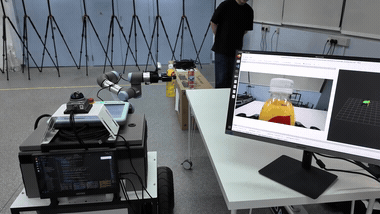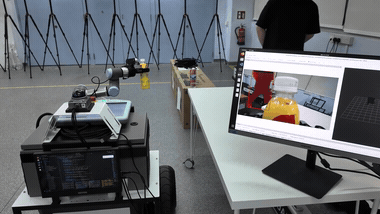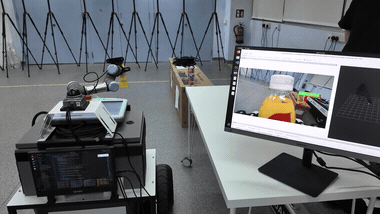
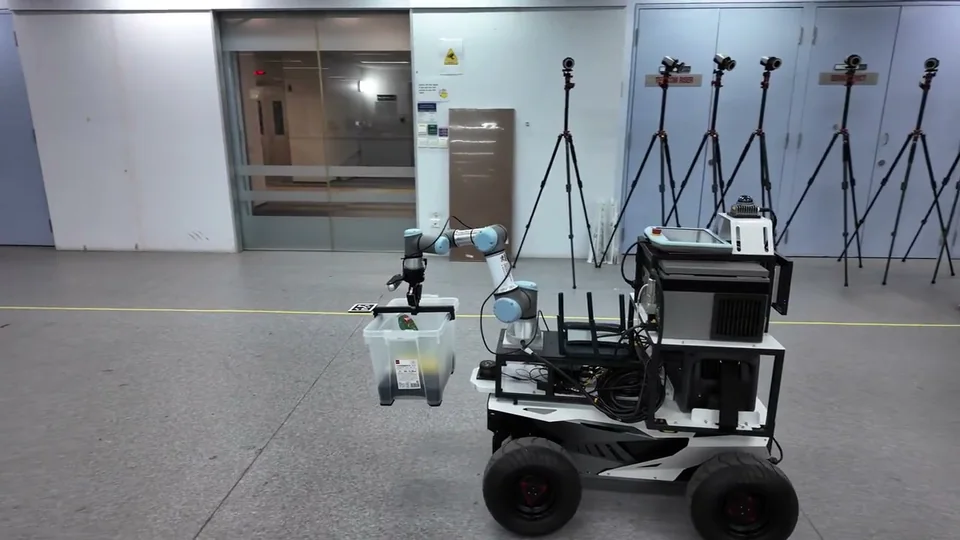
The base extends the arm’s reach beyond a fixed table. The main clip keeps the container, arm, and base in view through one complete transport sequence.
Hardware demonstration / EMBODIED SYSTEMS
Move to the task. Reach into the world.
A mobile manipulator moves between work areas, reaches for objects, and carries them through the lab.
01 / OVERVIEW
A mobile base and robot arm work together to move objects through the laboratory. One continuous demonstration follows a container from lift to transport and placement; a second shows a tabletop bottle pick-and-place sequence.
ROBOTICS IN MOTION · 50 sec
One continuous laboratory sequence shows the robot lifting a container, carrying it across the room, placing it down, and retracting its arm. Original playback speed is preserved.
ROBOTICS IN MOTION · 43 sec
A continuous tabletop pick-and-place sequence, from reaching for the bottle to releasing it and retracting the arm. Shown at the original playback speed.
02 / DEMONSTRATION
The arm lifts the container from the floor.
The mobile base travels with its payload.
The arm lowers and releases the container, then retracts.
The base extends the arm’s reach beyond a fixed table. The main clip keeps the container, arm, and base in view through one complete transport sequence.
Both clips continue through object release and arm retraction, so the result of each manipulation is visible.