See the recording setup
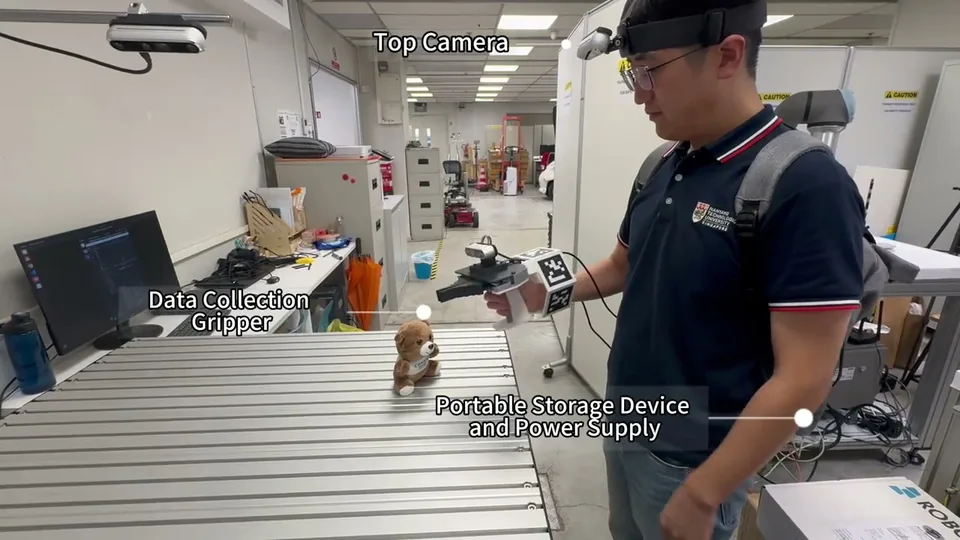
The opening labels identify the top camera, data-collection gripper, and portable storage and power supply.
Hardware demonstration / ROBOT LEARNING TOOLS
Capture the action and its context.
A portable gripper setup records human demonstrations alongside camera views, trajectories, and gripper signals.
01 / OVERVIEW
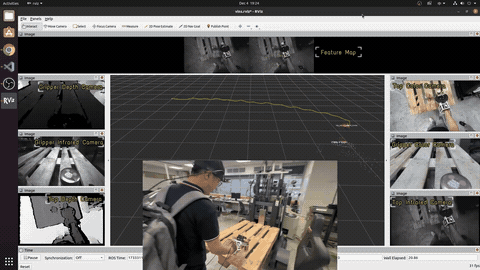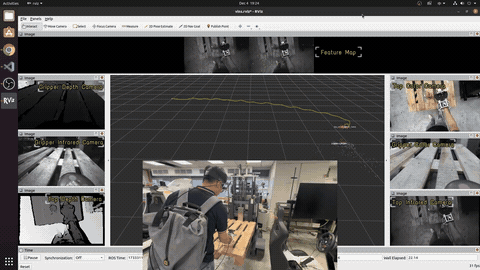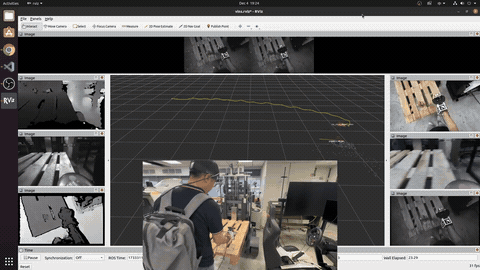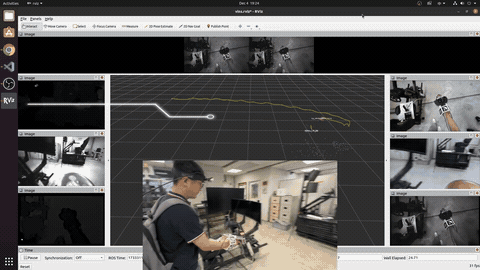
The demonstration pairs a handheld data-collection gripper with multiple camera views and a portable recording setup. The visualization follows the operator’s motion and displays the information captured during object handling.
ROBOTICS IN MOTION · 39 sec
The original data-collection demonstration, trimmed to 38.5 seconds. Hardware labels and the camera and trajectory displays are preserved.
02 / DEMONSTRATION
An operator demonstrates an object-handling task with the instrumented gripper.
The camera views capture the scene and the manipulation.
The display combines the trajectory and recorded gripper information.
The opening labels identify the top camera, data-collection gripper, and portable storage and power supply.
The remaining footage shows the camera streams and trajectory display as the operator moves between objects and work areas.