Use the environment as a reference
Raw scans provide the geometric structure needed for calibration.
IEEE IROS · 2025 / PERCEPTION & CONTROL
Calibrate on site, using the scene around you.
Target-free LiDAR–motor calibration for panoramic 3D sensing on a quadruped robot.
01 / OVERVIEW
LiMo-Calib: On-Site Fast LiDAR-Motor Calibration for Quadruped Robot-Based Panoramic 3D Sensing System
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) · 2025
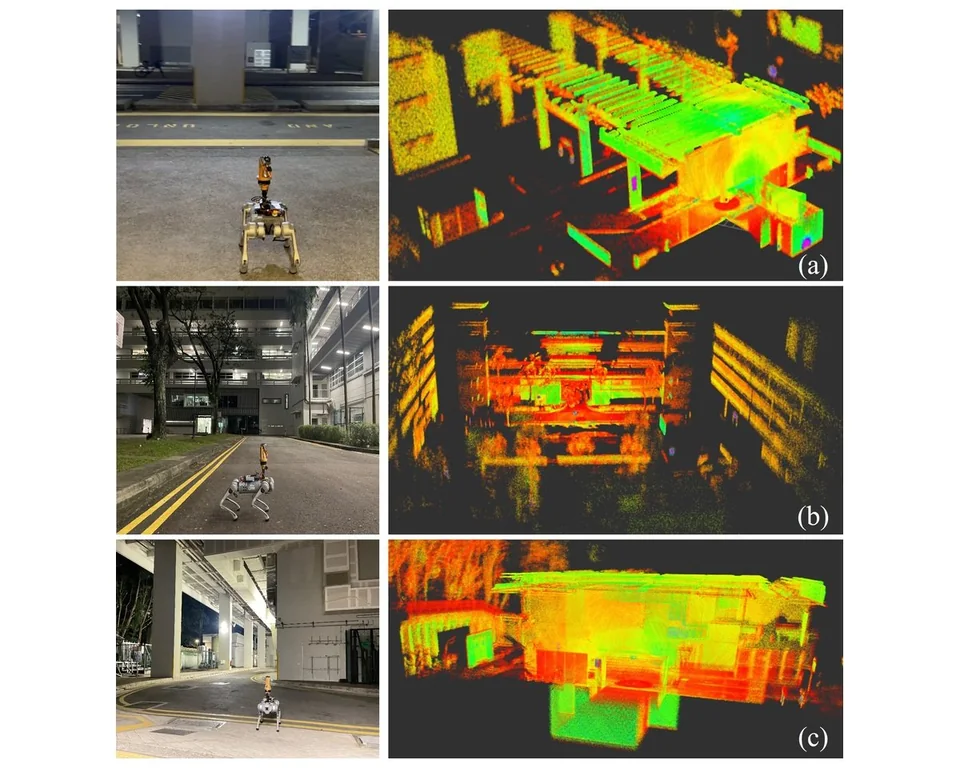
A motorized LiDAR expands a quadruped robot’s field of view, but its motor-to-sensor transform must be accurate. LiMo-Calib estimates this calibration from geometric features in LiDAR scans without requiring an external calibration target.
RESEARCH VISUALS
LiMo-Calib calibration demonstration from the authors’ public project.
02 / IMPLEMENTATION
Acquire raw LiDAR scans.
Choose geometric features using surface normals.
Optimize the LiDAR–motor transformation.
Apply the calibration to panoramic mapping.
Raw scans provide the geometric structure needed for calibration.
Normal-based selection and plane-quality weighting support robust estimation.
The calibrated parameters improve the consistency of the sensing system.
03 / RESOURCES
The paper, original demonstrations, and available project materials.