Couple individual decisions
Each robot contributes a local objective to the shared optimization.
Unmanned Systems · 2024 / COLLABORATIVE CONTROL
Find a lifting configuration together.
Distributed optimization of robot positions for cooperative lifting with multiple aerial robots.
01 / OVERVIEW
A Distributed Optimization Approach for Collaborative Object Lifting Using Multiple Aerial Robots
Unmanned Systems · 2024
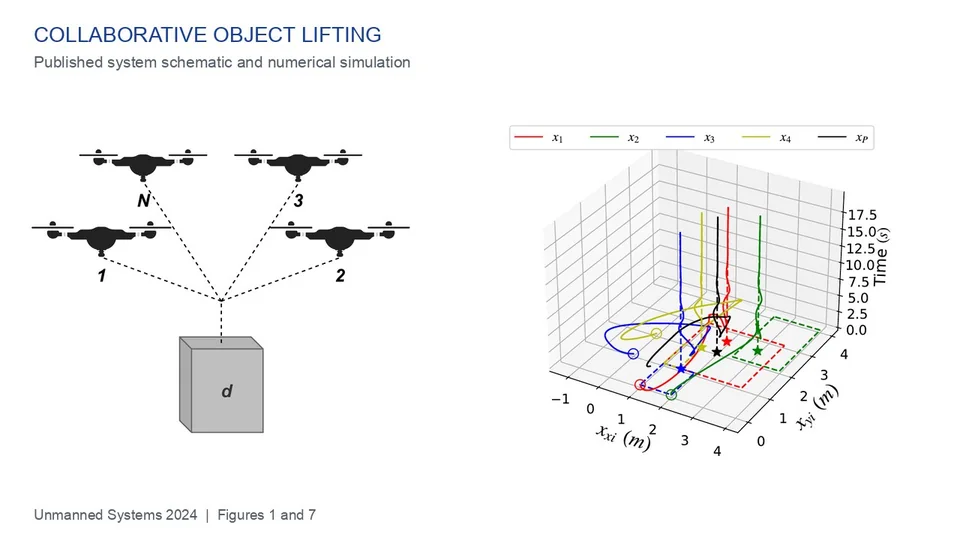
Collaborative lifting couples the choices of every robot. This work formulates those choices as a distributed optimization problem, accounting for individual objectives, feasible positions, and the force balance of the team.
RESEARCH VISUALS
Original figures from the published paper: system schematic and numerical simulation trajectories. This study reports simulation results, not flight experiments.
02 / IMPLEMENTATION
Describe each robot’s objective.
Account for feasible positions and force balance.
Exchange information with neighboring robots.
Converge toward a cooperative configuration.
Each robot contributes a local objective to the shared optimization.
The formulation accounts for constraints imposed by the payload.
Numerical results evaluate the proposed distributed algorithms.
03 / RESOURCES
The paper, original demonstrations, and available project materials.