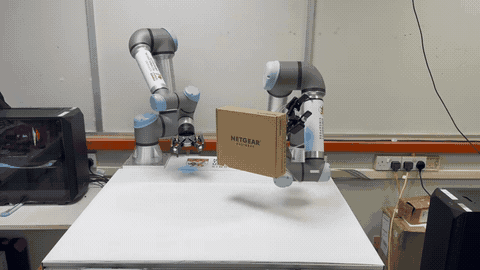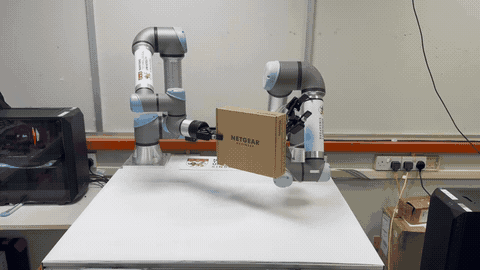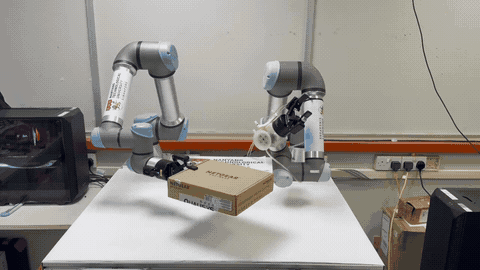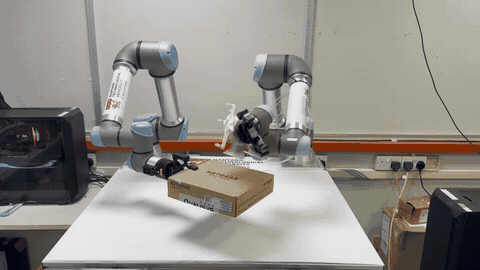
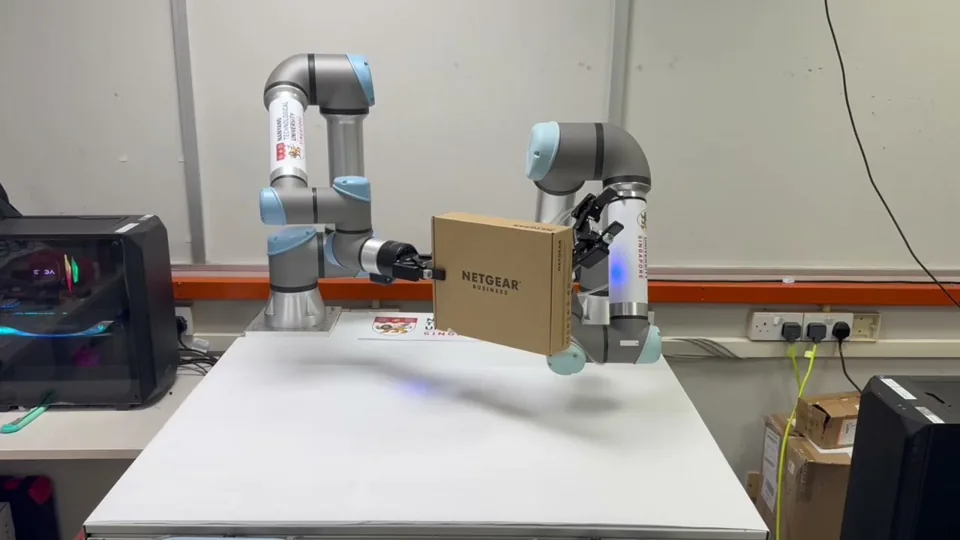
Pass the box between arms
The first demonstration follows both grippers from pickup through handoff and regrasp to final placement. The package-transfer clip shows one continuous grasp-and-release cycle with a flexible object.
Hardware demonstration / OBJECT INTERACTION
Different objects. Different interactions.
Three demonstrations show a complete two-arm box handoff, tabletop rearrangement, and a flexible-package transfer.
01 / OVERVIEW
Objects introduce different handling challenges: flexible items change shape, a box needs a stable transfer, and a tabletop task involves several object types. These demonstrations show three laboratory setups for exploring those interactions.
ROBOTICS IN MOTION · 20 sec
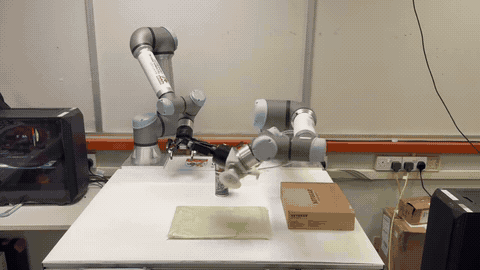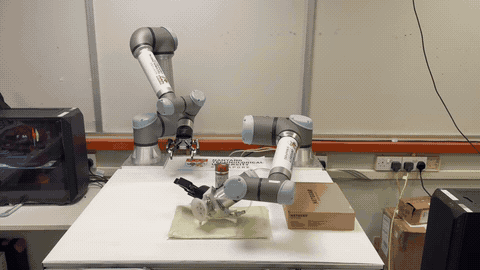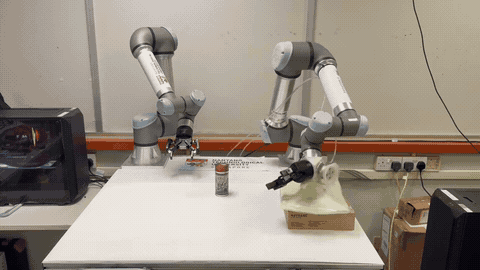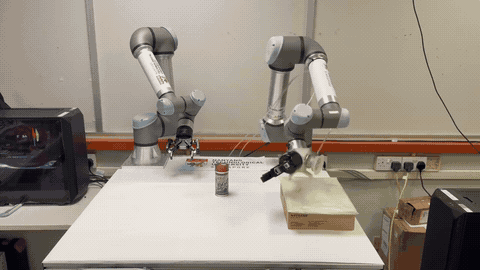
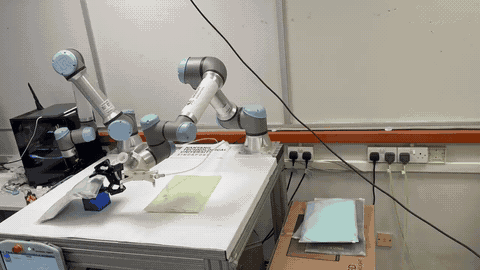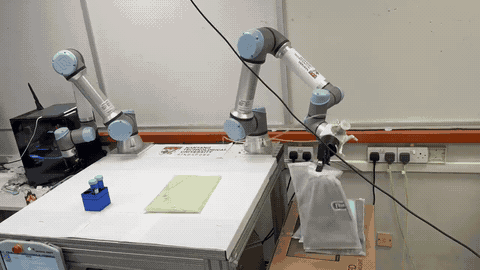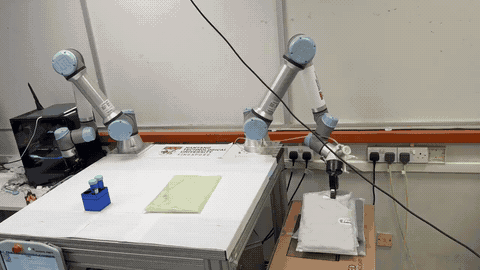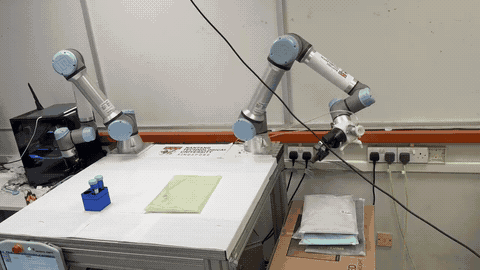
Two arms pick up, hand off, regrasp, and place a cardboard box. The complete short demonstration retains the original view and timing.
ROBOTICS IN MOTION · 28 sec
A robot arm moves a cylindrical container, relocates a box, places a flexible package on the box, and returns the container to the top. The complete sequence retains the original timing.
ROBOTICS IN MOTION · 14 sec
One continuous transfer of a flexible package: grasp, lift, placement on the adjacent stack, release, and arm return. Shown at the original playback speed.
02 / DEMONSTRATION
The robot brings its gripper to the object.
The object is grasped, moved, or passed between arms.
The robot releases the object at a new location.
The first demonstration follows both grippers from pickup through handoff and regrasp to final placement. The package-transfer clip shows one continuous grasp-and-release cycle with a flexible object.
The tabletop demonstration shows a cylindrical container, box, and flexible package being repositioned in sequence. Each clip retains the original view of the setup.