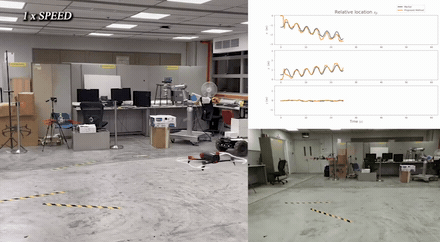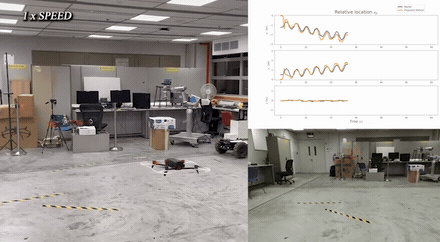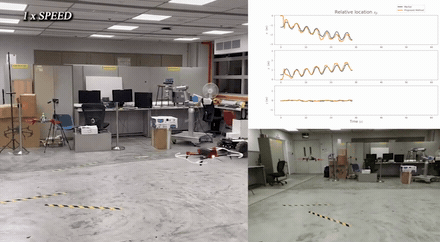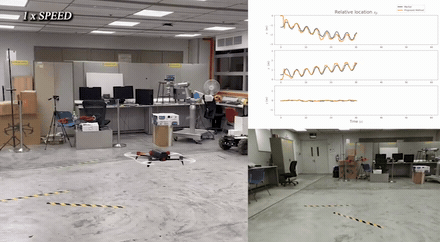
Flight and plots together
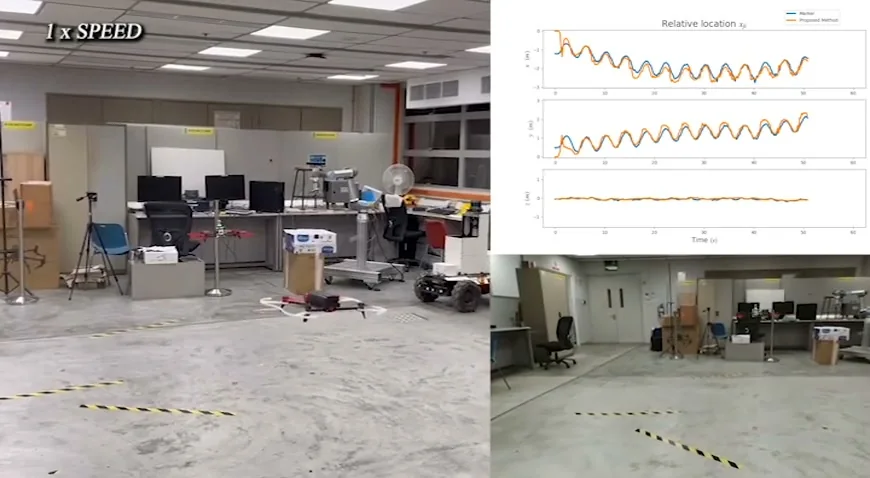
The recording preserves the original layout, including the full view of the robot, the smaller camera view, and the three plotted coordinates.
Hardware demonstration / VISION-BASED ESTIMATION
Track relative motion through vision.
A drone flight demonstration pairs a monocular relative-position estimate with live trajectories and camera views.
01 / OVERVIEW
The demonstration shows a flying robot alongside a second view of the scene and live relative-location plots. Keeping the footage and curves together makes it possible to follow the robot’s motion and the changing estimate throughout the recorded tracking trial.
ROBOTICS IN MOTION · 60 sec
The full recorded tracking trial, from the initial estimates to the final plotted trajectories. The camera views, coordinate plots, and original 1× playback label are preserved.
02 / DEMONSTRATION
The camera observes the moving robot.
Relative-location estimates update as the robot moves.
The plots and laboratory footage can be followed side by side.
The recording preserves the original layout, including the full view of the robot, the smaller camera view, and the three plotted coordinates.
All 60 seconds of the source recording are shown without internal cuts or changes in playback speed. The footage shows an ongoing flight with synchronized estimates.