A spatial view of allocation
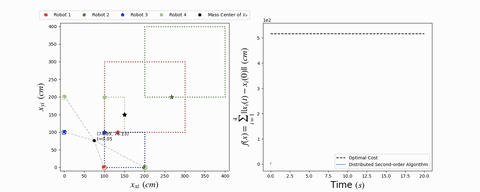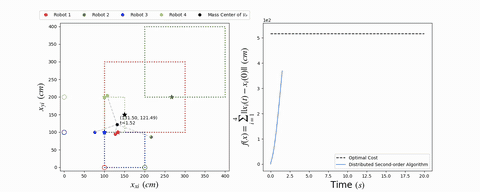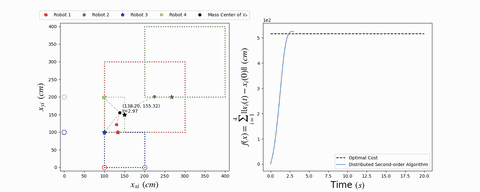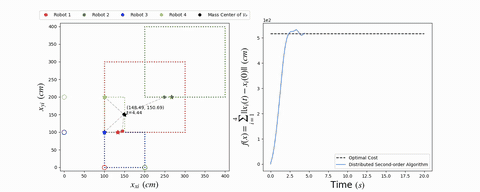
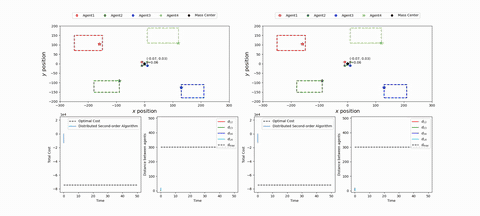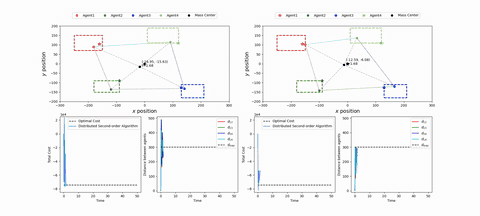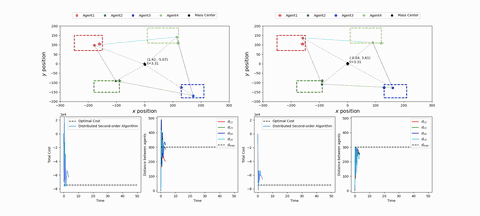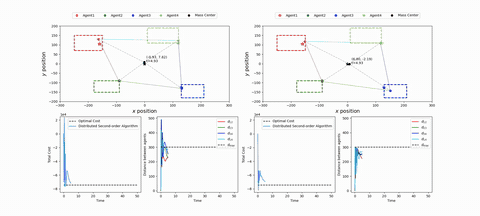
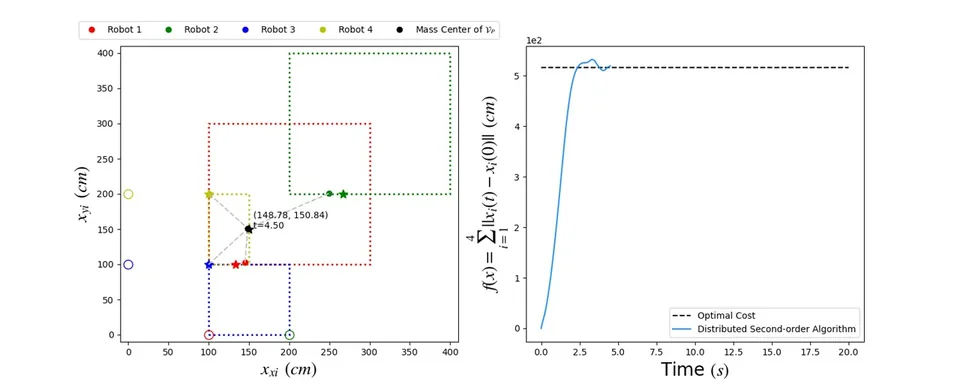
The first animation shows four robot positions, local feasible regions, and the mass center. Its objective measures the sum of displacements from the initial locations, with a dashed optimal-cost reference.
Simulation study / MULTI-AGENT OPTIMIZATION
Local motion, collective structure.
Four-agent simulation studies visualize position updates, spatial constraints, and the evolving group configuration.
01 / OVERVIEW
These presentation simulations follow four agents as their positions evolve within a shared task. The animations make the spatial configuration visible over time, including a lifting-related allocation study and a second comparison shown in parallel panels.
ROBOTICS IN MOTION · 22 sec
Original presentation simulation. This animation shows a four-agent allocation study; it is presented separately from the published lifting-paper experiments.
ROBOTICS IN MOTION · 30 sec
An excerpt from the original two-panel presentation simulation. Axes, legends, and trajectories are retained.
02 / DEMONSTRATION
The four agents start from their displayed positions.
The agents move as the simulated allocation evolves.
The traces and final configuration reveal the resulting arrangement.
The first animation shows four robot positions, local feasible regions, and the mass center. Its objective measures the sum of displacements from the initial locations, with a dashed optimal-cost reference.
The second animation compares two four-agent cases. Each panel shows positions, total cost, and pairwise distances d12, d13, and d14 against the distance limit dmax.