From the table to the team
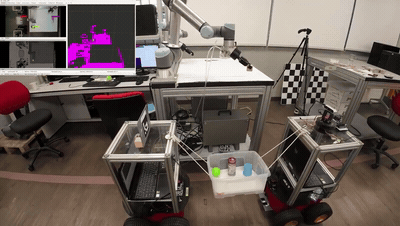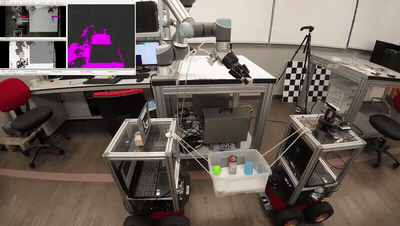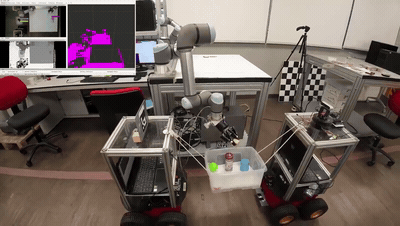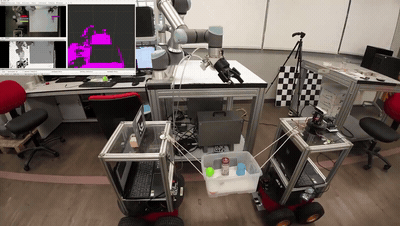
The first clip connects manipulation to transport, preserving the semantic-perception inset and the original explanatory captions.
Hardware demonstration / MULTI-ROBOT COORDINATION
Manipulation meets coordinated motion.
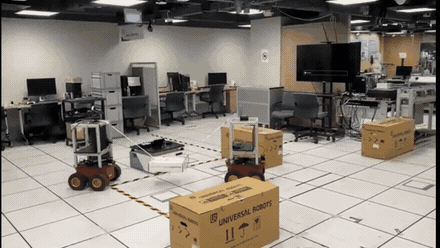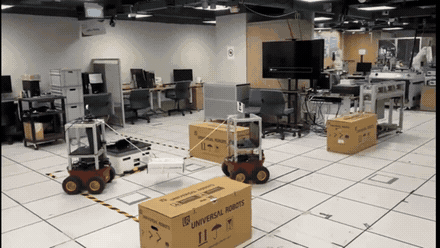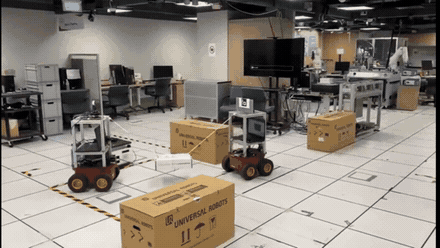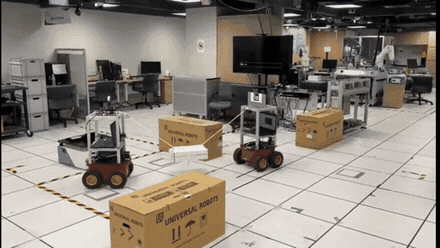
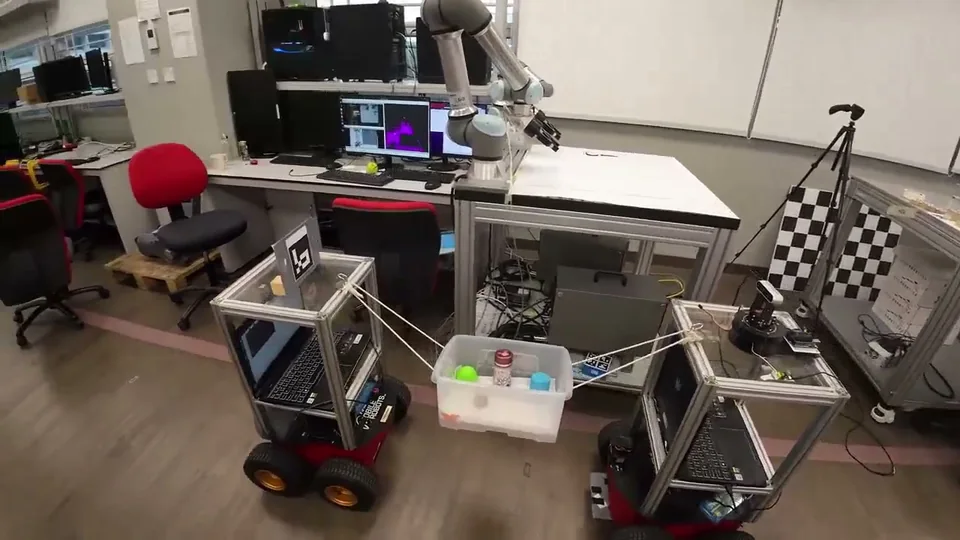
A robot arm loads a shared tray, then a pair of mobile robots carries it through an obstacle-filled workspace.
01 / OVERVIEW
This project combines object selection and loading with cooperative transport. A fixed arm places objects into a shared tray; two mobile platforms then move the payload through the laboratory. A second demonstration focuses on the paired robots maneuvering around boxes.
ROBOTICS IN MOTION · 47 sec
A continuous sequence connects the final object placement, arm retraction, and shared-tray departure to the recorded obstacle route. Original captions and the perception inset are retained.
ROBOTICS IN MOTION · 33 sec
A continuous excerpt (1–34 s) showing a pair of mobile robots transporting a shared payload around obstacles.
02 / DEMONSTRATION
The arm selects objects and places them into the tray.
The two mobile platforms support and move the shared payload.
The team transports the load through the surrounding workspace.
The first clip connects manipulation to transport, preserving the semantic-perception inset and the original explanatory captions.
The second clip keeps a continuous view of the two-robot maneuver through a field of boxes.